Adaptive space partition: how the Voronoi cells are refined
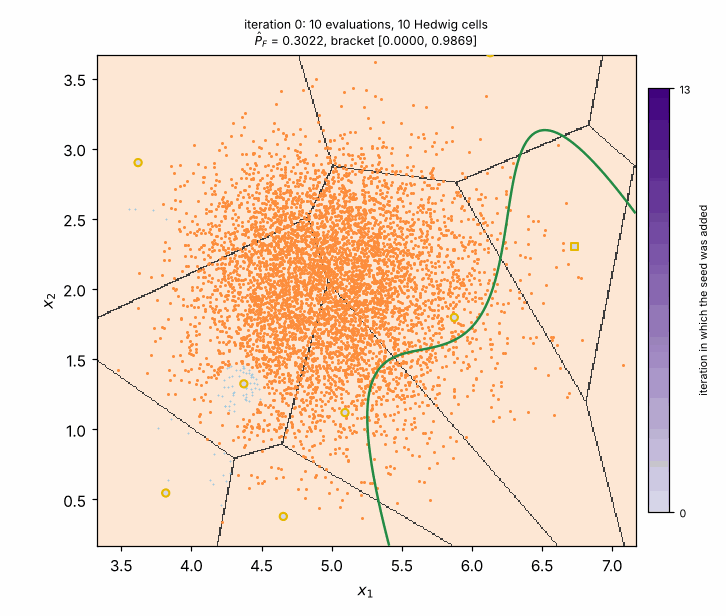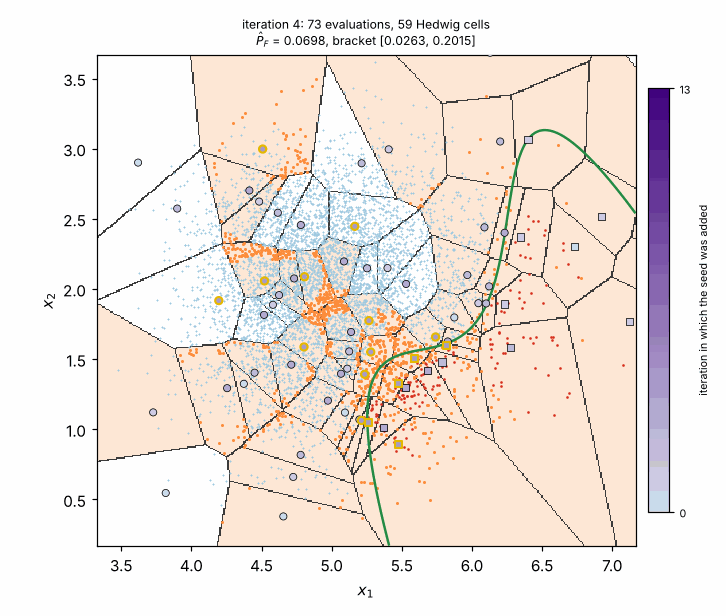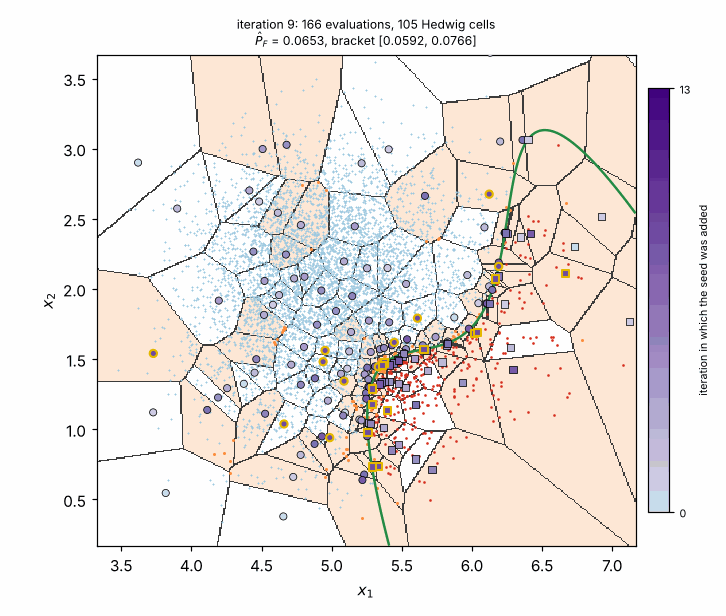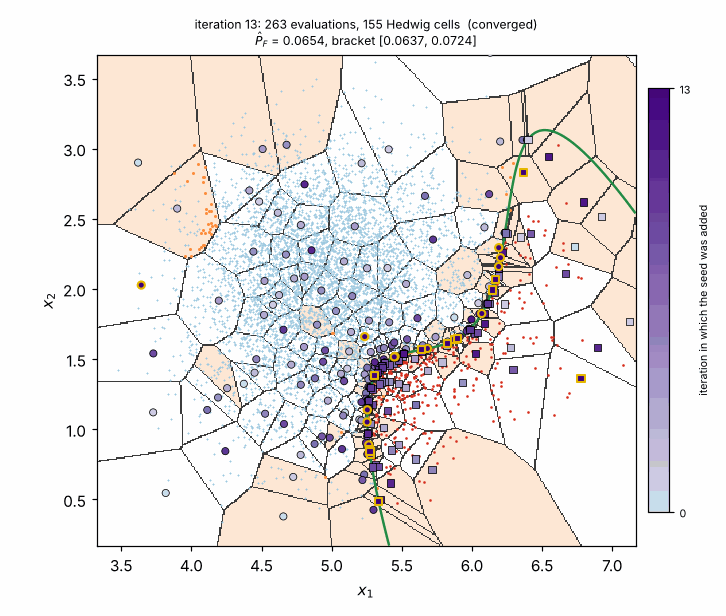
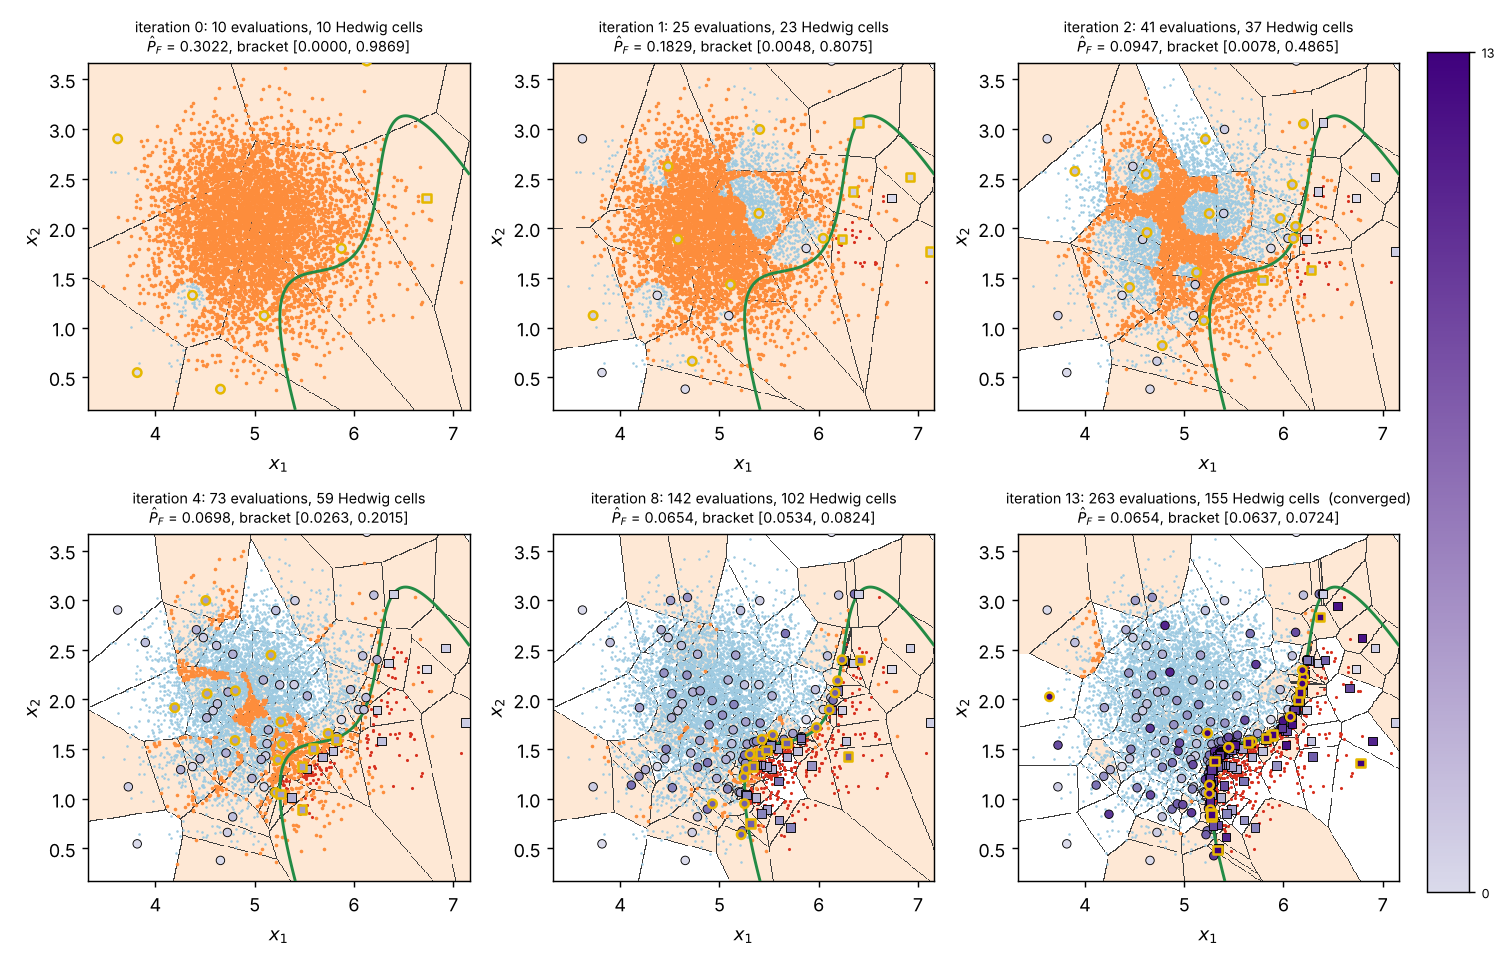
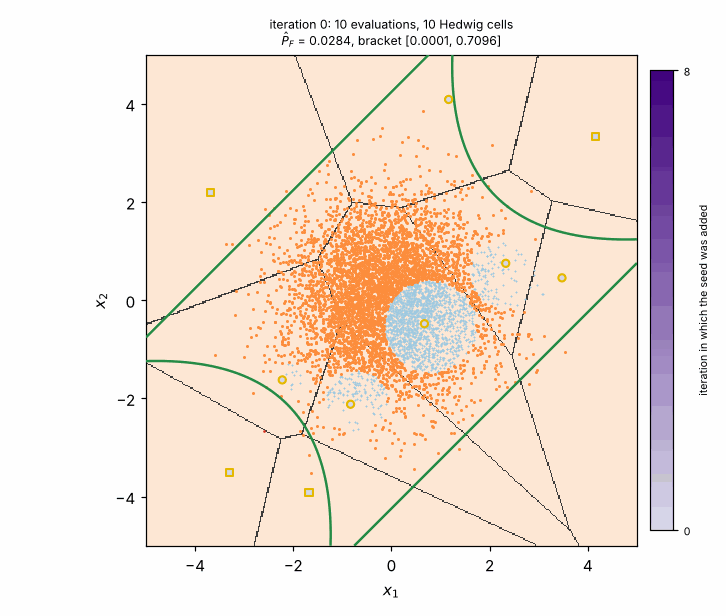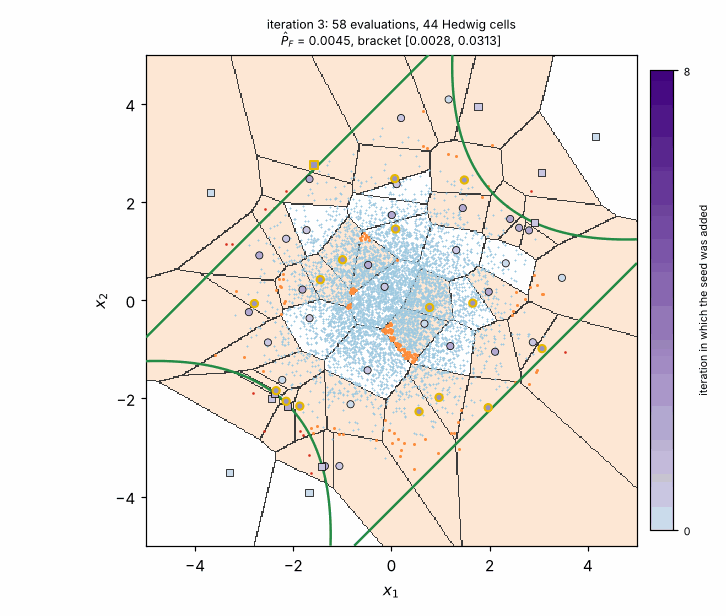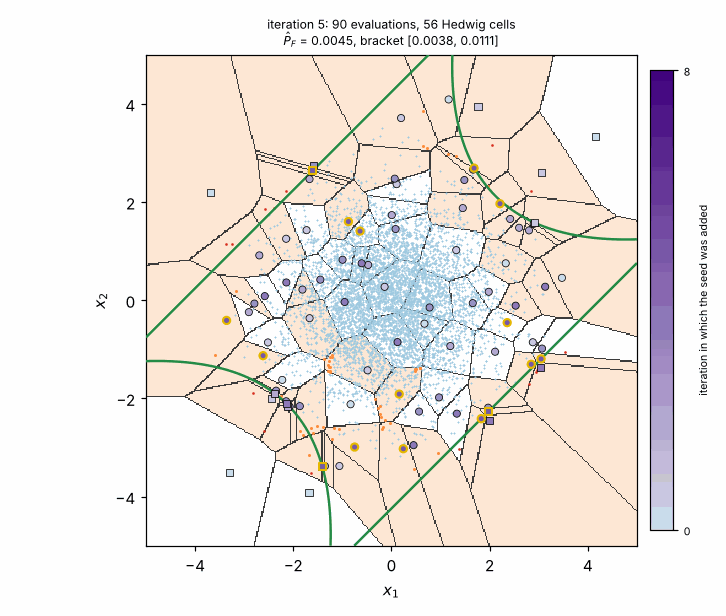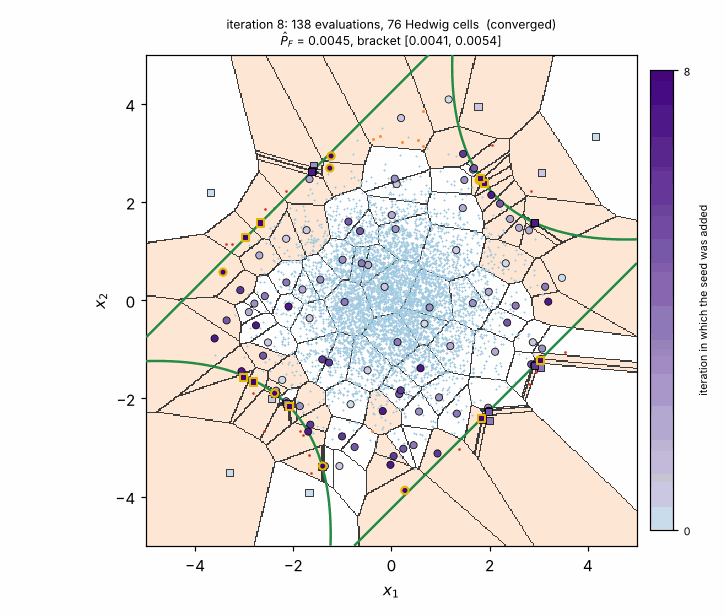
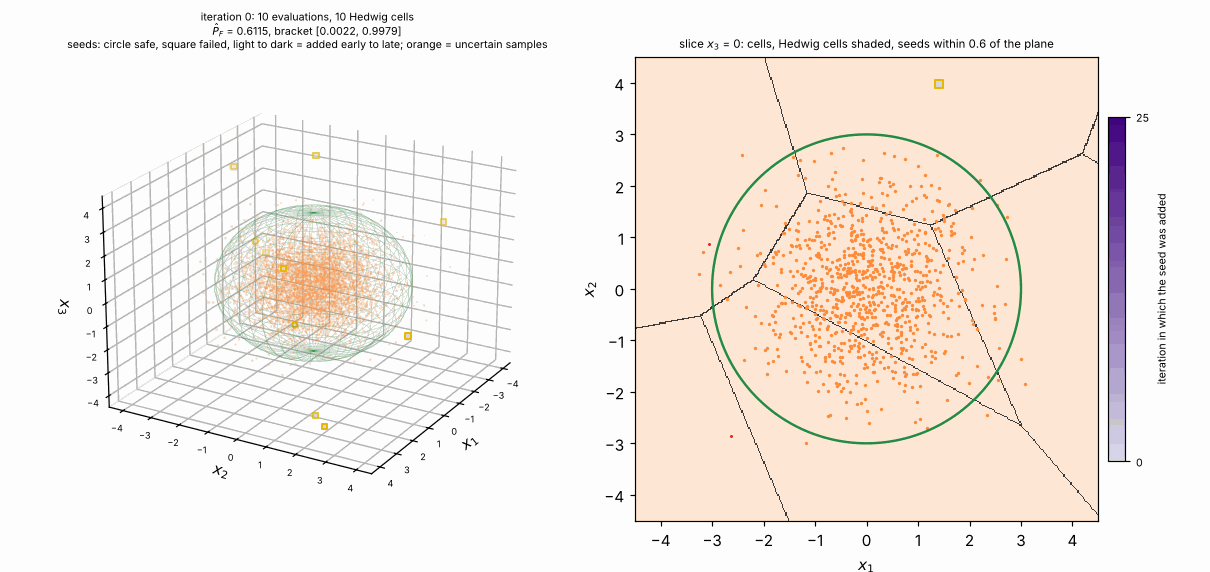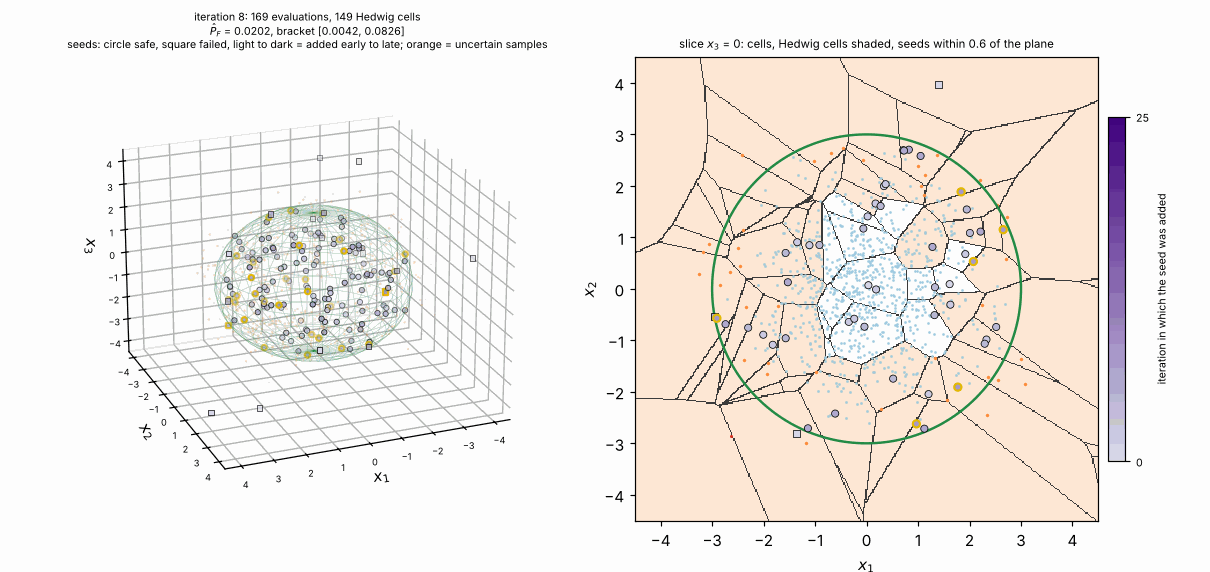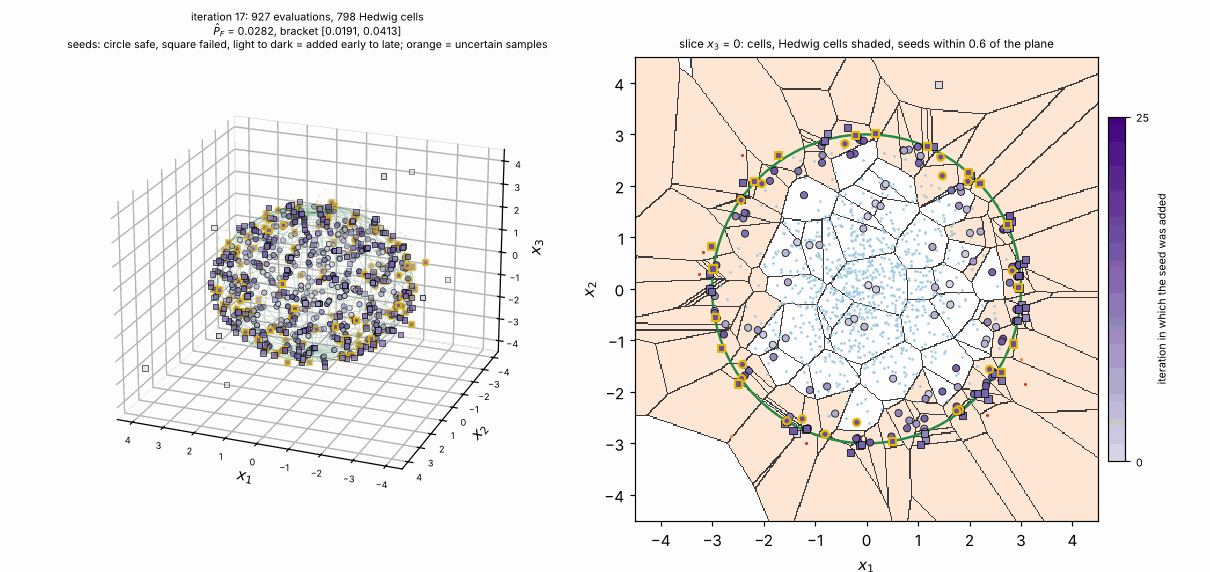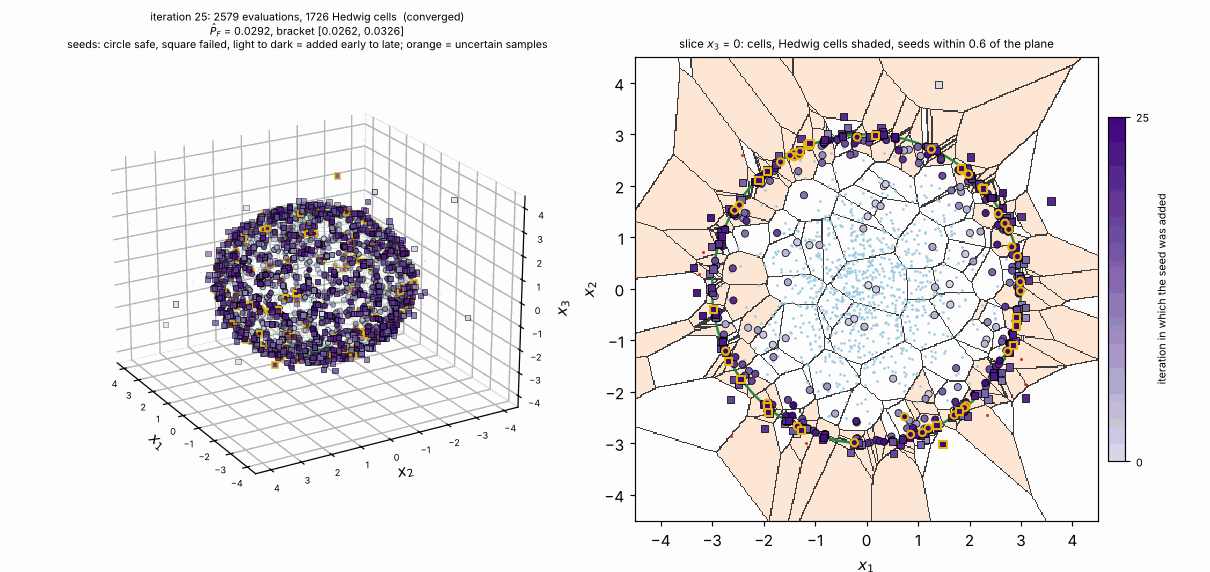
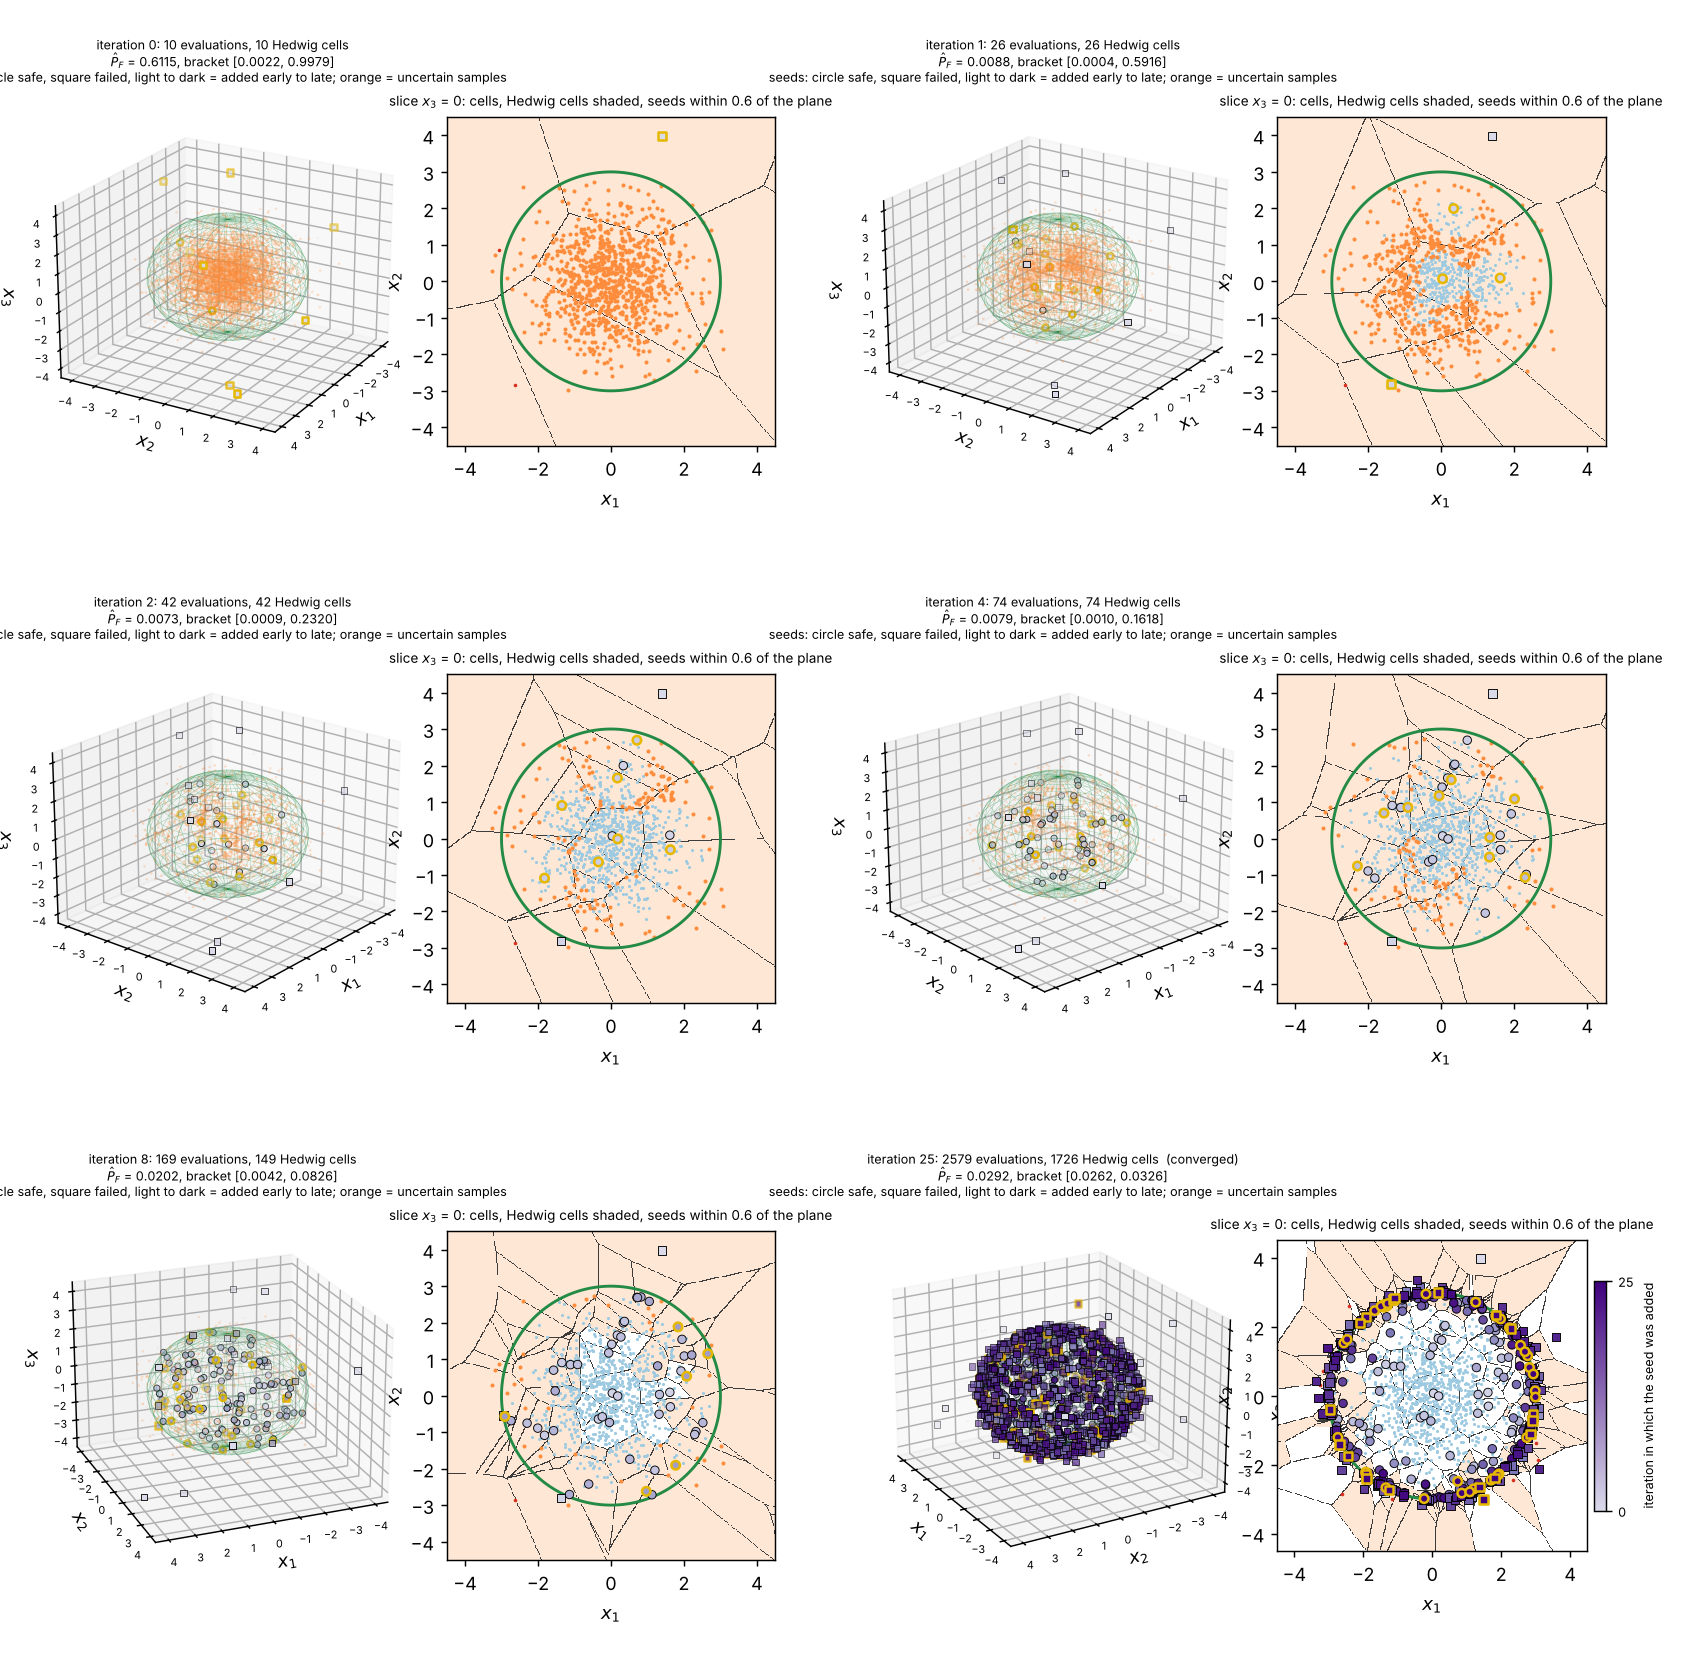
Reliability analysis by an adaptive space partition (ASP). A large Monte Carlo population is assigned to the nearest seed; the performance function is evaluated only at the seeds. A Hedwig cell is a cell whose classification is not settled. New seeds enter Hedwig cells only, so the cells are refined along the limit state and stay coarse elsewhere. Each frame is one iteration of the actual algorithm.
- safe sample
- failed sample
- uncertain sample
- Hedwig cell (shaded)
- limit state g = 0
- →seed, light to dark = added early to late
- square = failed seed, circle = safe seed
- gold edge = added in this iteration
Thesis 2-D test problem (hook)
Lognormal and Weibull inputs, G2 hook performance function of the thesis, P_F = 6.5 %. The ten initial seeds cover the sample box; the hook is found and traced along its whole length.
14 iterations, 263 evaluations; estimate 0.0654, bracket [0.0637, 0.0724], Monte Carlo on the same population 0.0654
Four-branch series system (Echard et al. 2011)
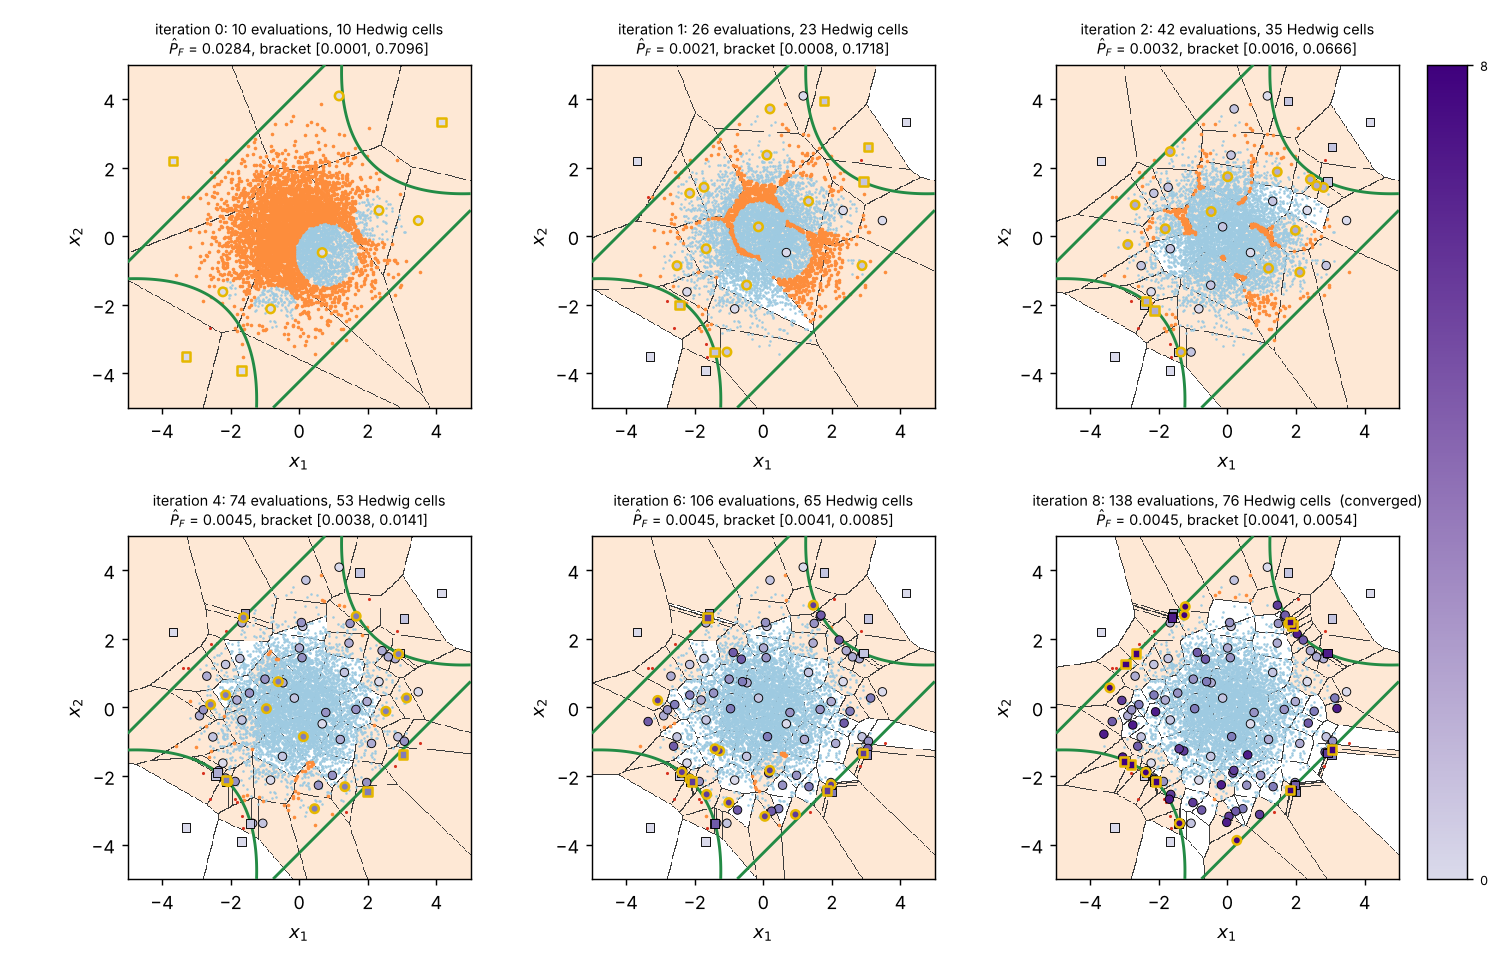
Standard normal inputs, four failure branches, P_F = 0.45 %. None of the initial seeds lies in a failure region; the margin marks the far samples uncertain, acquisition goes there, and all four branches are found.
9 iterations, 138 evaluations; estimate 0.0045, bracket [0.0041, 0.0054], Monte Carlo on the same population 0.0045
3-D open surface with two failure modes
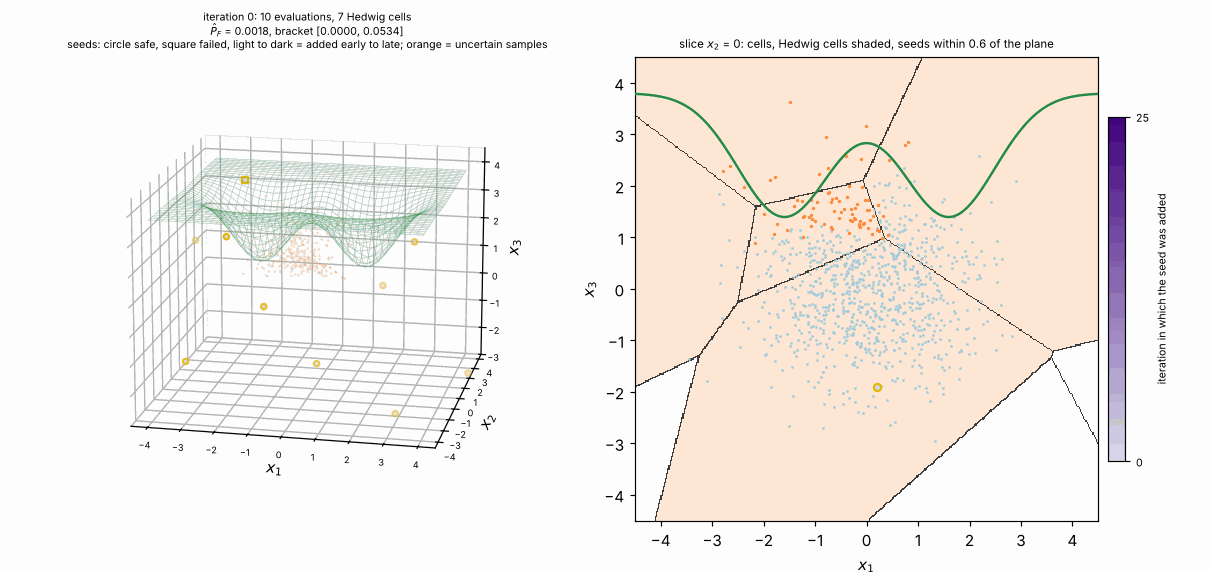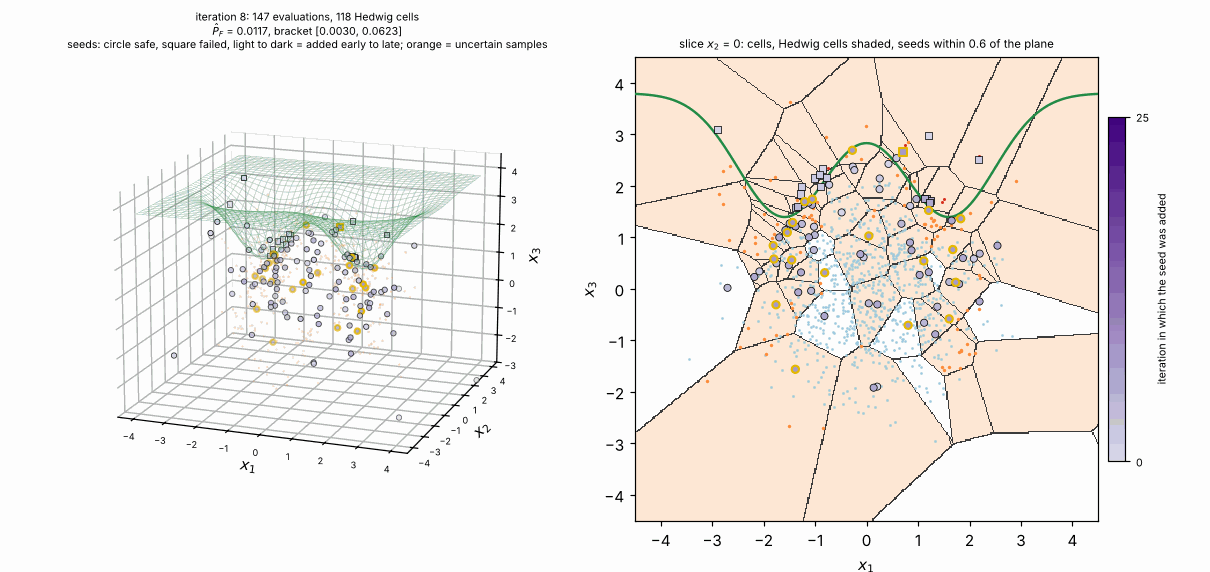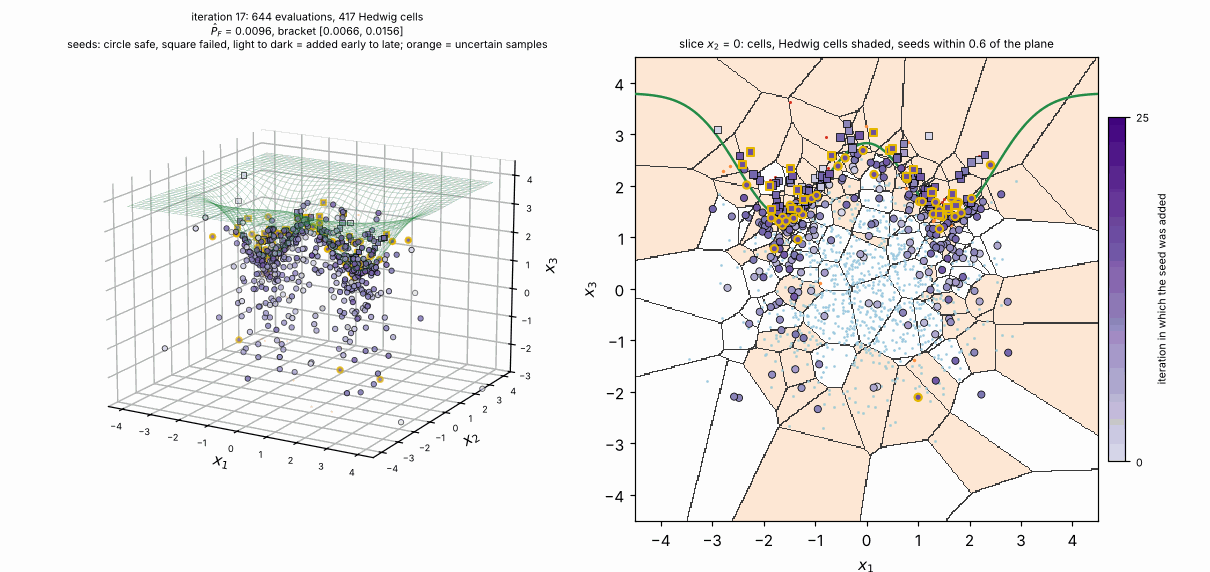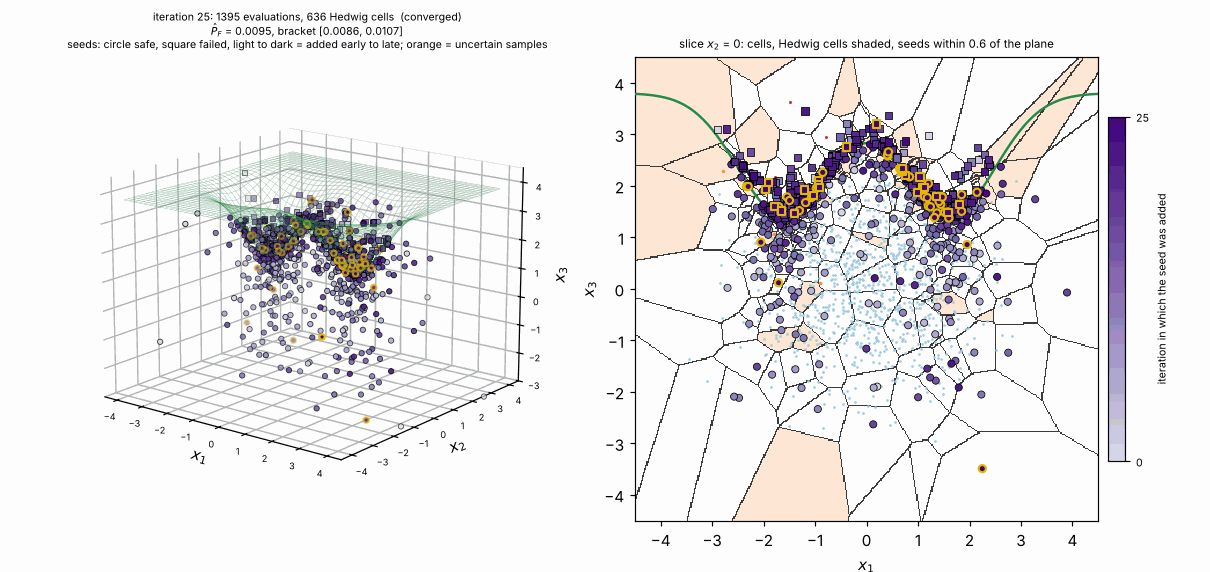
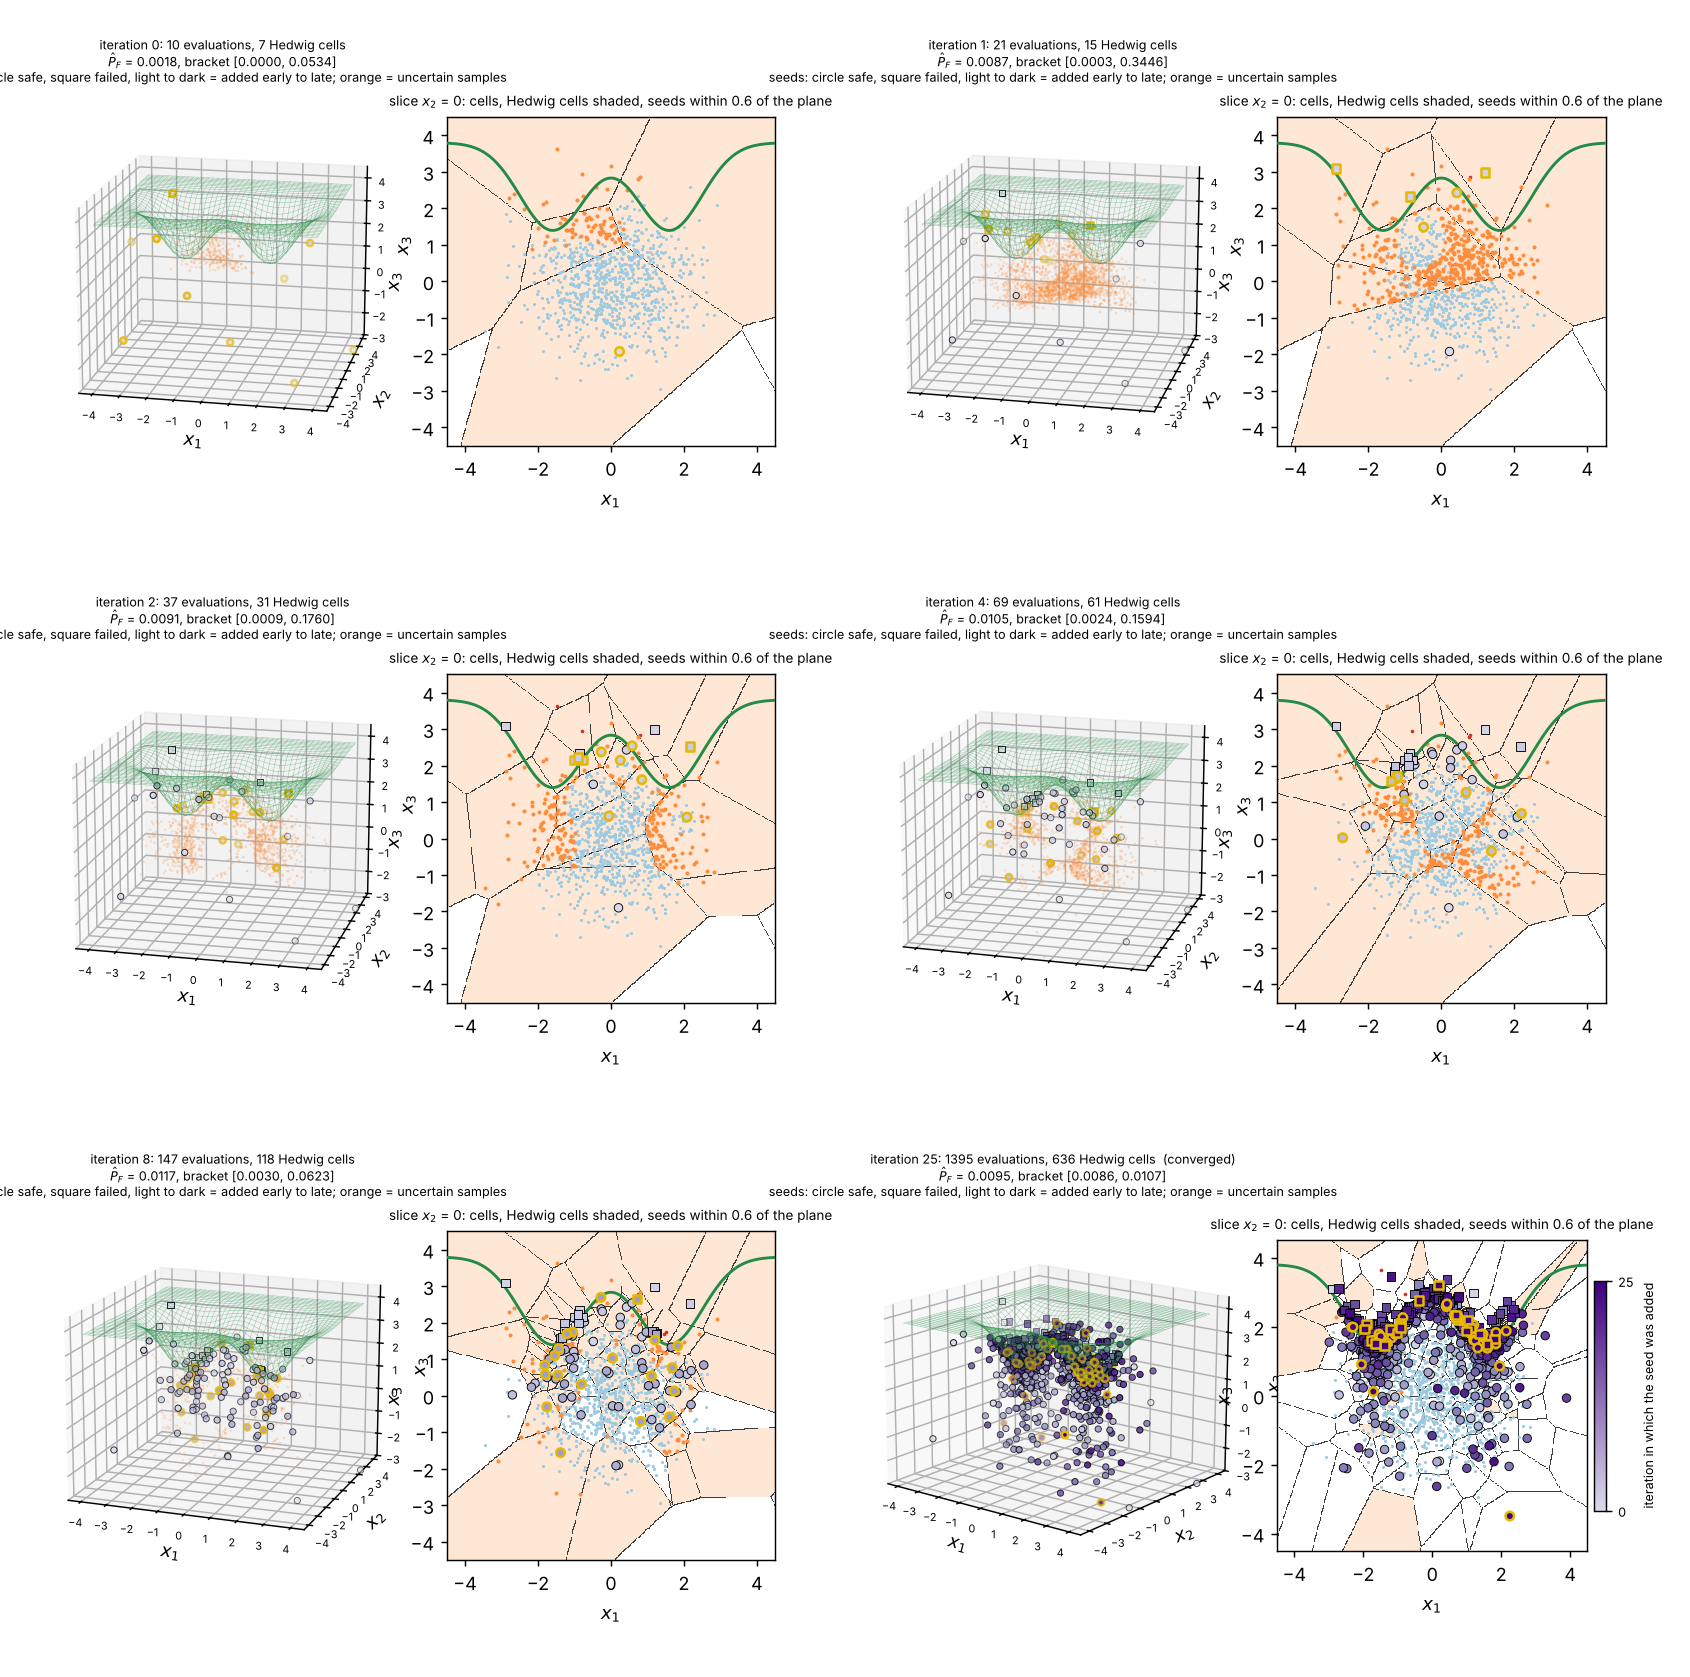
x ~ N(0, I_3), g = x_3 - h(x_1, x_2) with a two-well terrain h, P_F = 0.95 %. Left: seeds and uncertain samples under the surface. Right: the cells cut by the plane x_2 = 0 through both wells. Seeds accumulate in the two wells only.
26 iterations, 1395 evaluations; estimate 0.0095, bracket [0.0086, 0.0107], Monte Carlo on the same population 0.0095
3-D closed surface (sphere)
x ~ N(0, I_3), g = |x|^2 - 9, P_F = 2.93 %. A closed limit-state surface has to be covered entirely, which is why this example needs the most evaluations; the slice is x_3 = 0.
26 iterations, 2579 evaluations; estimate 0.0292, bracket [0.0262, 0.0326], Monte Carlo on the same population 0.0297, exact 0.0293
Files
Each example: the animation (GIF), six selected iterations as one figure (PNG, PDF), and the per-iteration numbers (JSON). Generated by scripts/animate_asp.py of the hedwig package (N = 2 × 10⁵ samples, bound tolerance 5 %, batch 16).
- hook.gif
- fig_partition_steps_hook.png
- fig_partition_steps_hook.pdf
- hook_snapshots.json
- four_branch.gif
- fig_partition_steps_four_branch.png
- fig_partition_steps_four_branch.pdf
- four_branch_snapshots.json
- twinpeaks3d.gif
- fig_partition_steps_twinpeaks3d.png
- fig_partition_steps_twinpeaks3d.pdf
- twinpeaks3d_snapshots.json
- sphere3d.gif
- fig_partition_steps_sphere3d.png
- fig_partition_steps_sphere3d.pdf
- sphere3d_snapshots.json